


Zihao Zhang, Haochen Tian, Tianyu Li, Changhui Jing, Jingliang He, Naisheng Ye, Ziyuan Pu, Zhenjie Yang
- 📧 Primary Contact: Zihao Zhang (zihao.zhang@opendrivelab.com)
- 🖊️ Joint effort by SEU, OpenDriveLab at HKU, and SLAI.
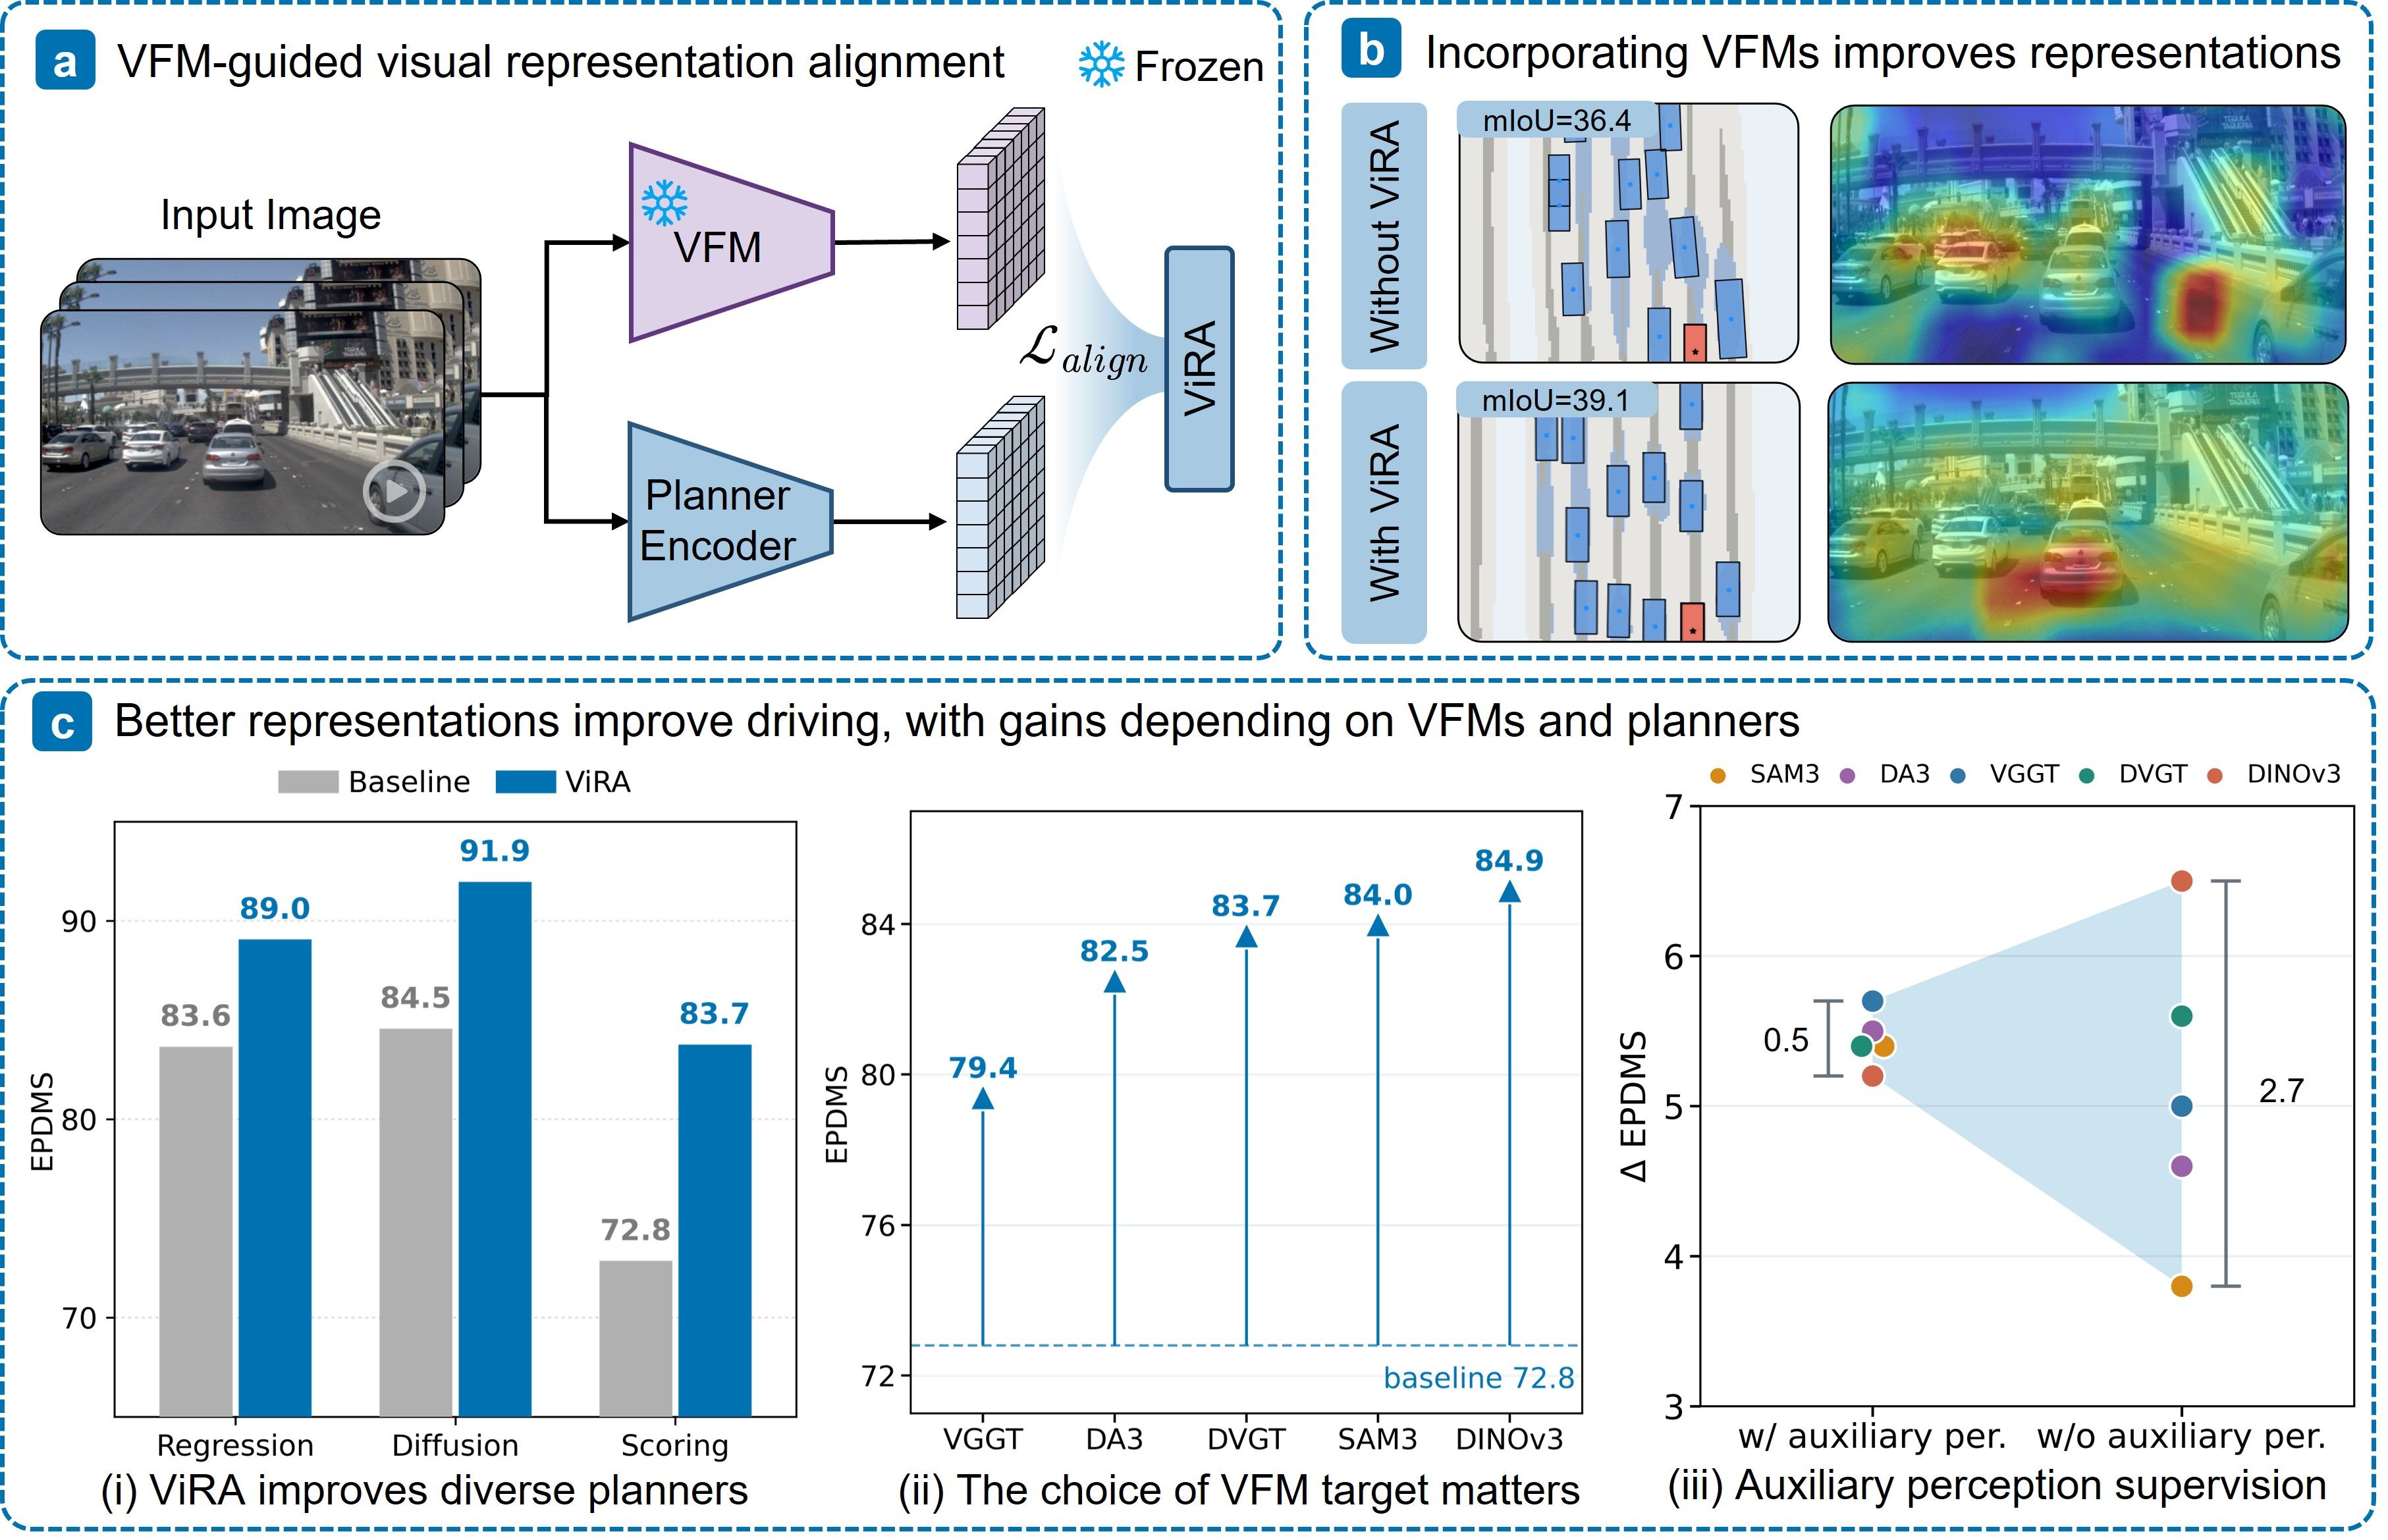
- 🚗 Planner-agnostic alignment: ViRA improves driving across diverse end-to-end planners without changing their deployed architecture or inference cost.
- 🔍 Target selection and supervision matter: VFM target choice affects planning gains, while auxiliary perception supervision narrows performance differences across targets.
- 📈 ViRA-Diffusion: DINOv3 alignment enables 92.3 EPDMS on NAVSIM v2 navtest without auxiliary perception supervision.
-
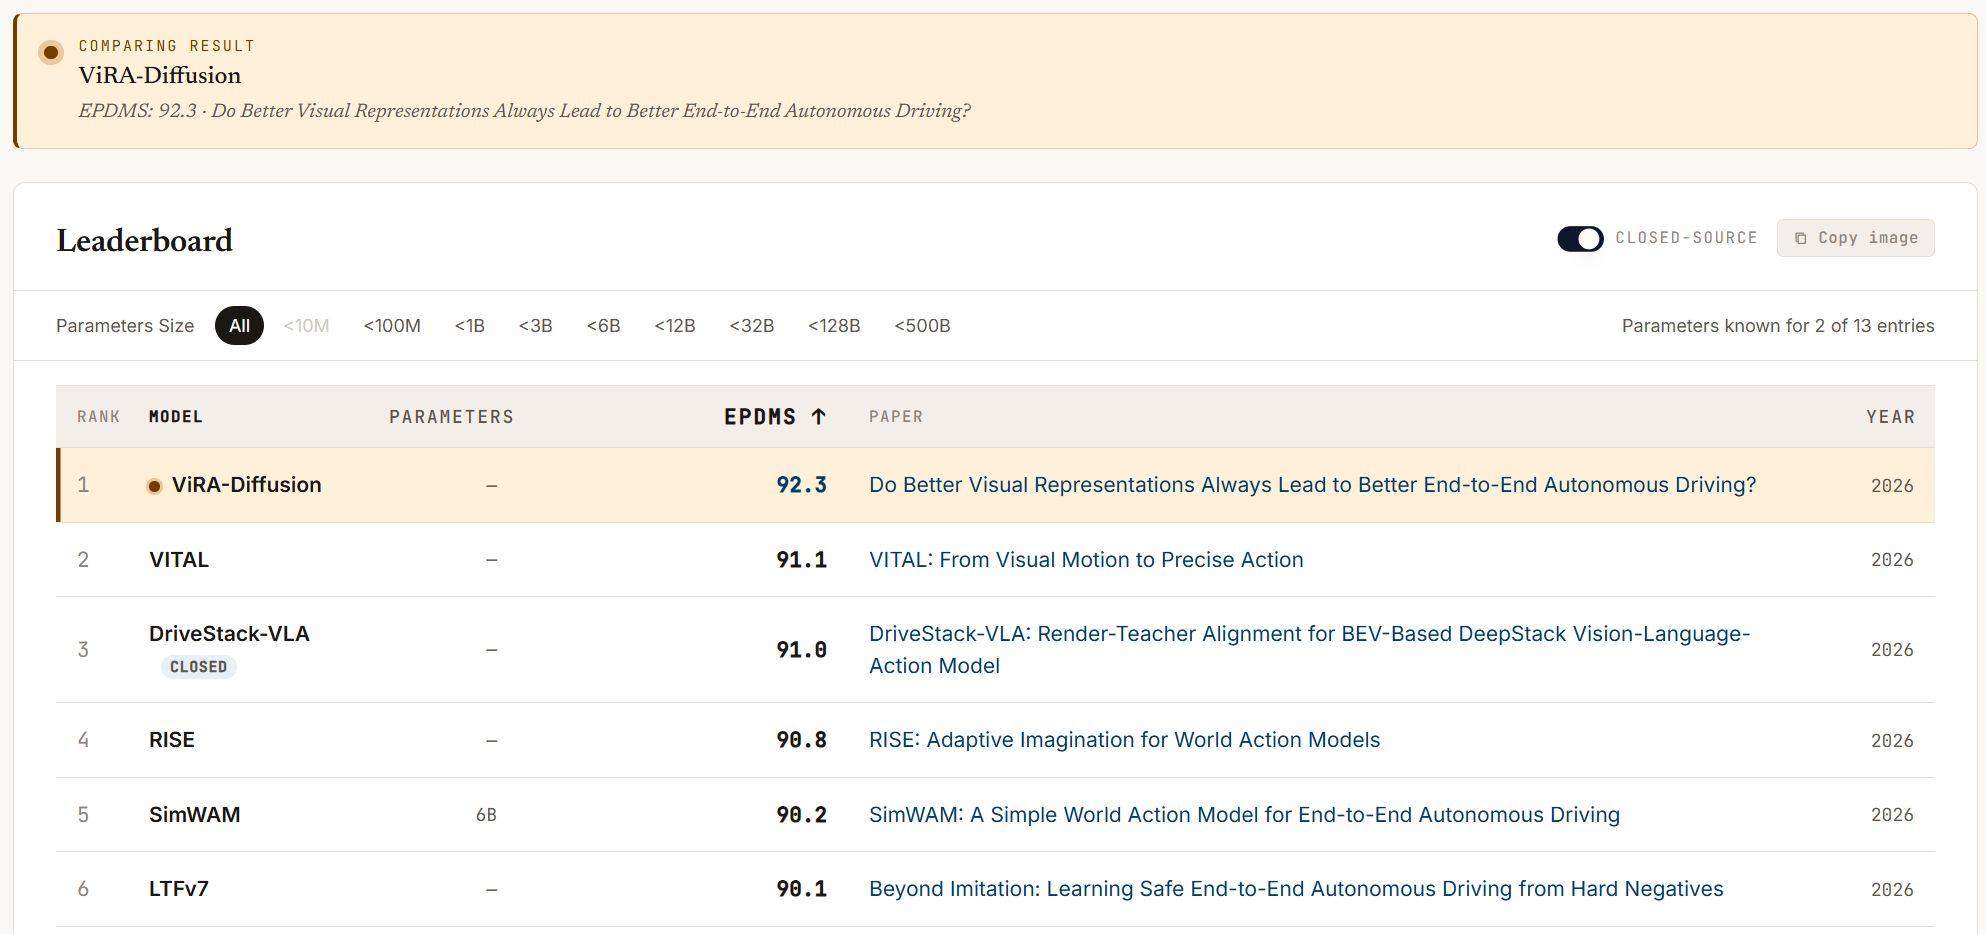
[2026/10/23]As of October 23, 2026, ViRA-Diffusion ranks first on the Papers with Code NAVSIM v2 navtest benchmark. -
[2026/10/22]We released the code and checkpoints of ViRA-Diffusion. -
[2026/10/7]We released our paper on arXiv.

- Results and Demo release.
- ViRA-Diffusion inference code and checkpoints.
- All Code release.
- All Checkpoints release.
git clone https://github.com/OpenDriveLab/ViRA
cd ViRAconda env create --name vira -f environment.yml
conda activate vira
pip install -e .Prepare the NAVSIM OpenScene data as described in NAVSIM. Download the ViRA-Diffusion checkpoints from Hugging Face into ckpts/. Generate the navtest metric cache and place it at the path below. The trajectory anchor is already in the repository.
ViRA/
├── datasets/
│   ├── maps/                  # NUPLAN_MAPS_ROOT, nuplan-maps-v1.0
│   ├── navsim_logs/
│   ├── sensor_blobs/
│   ├── warmup_two_stage/
│   └── navhard_two_stage/
├── navsim/traj_final/kmeans_navsim_traj_20.npy
├── exp/cache/navsim_v2_eval_cache/navtest_metric_cache/
└── ckpts/
    ├── resnet34.bin
    └── vira_diffusion.ckpt
bash ./scripts/evaluation_navtest/run_vira_diffusion_evaluation.shCamera-only. Rap* is our reimplementation with a different backbone and without the original data augmentation. HUGSIM is zero-shot: planners are trained only on NAVSIM.
| Method | Decoder | NAVSIM v2 navtest | NAVSIM v2 navhard | HUGSIM |
|---|---|---|---|---|
| EPDMS | EPDMS | HD-Score | ||
| Perception-based | ||||
| TransFuser | Regression | 83.6 | 27.6 | 22.1 |
| TransFuser-ViRA | 89.0 | +5.4 | 31.7 | +4.1 | 24.8 | +2.7 | |
| DiffusionDrive | Diffusion | 84.5 | 30.5 | 22.2 |
| DiffusionDrive-ViRA | 91.9 | +7.4 | 35.8 | +5.3 | 28.6 | +6.4 | |
| Perception-free | ||||
| Rap* | Scoring | 72.8 | 32.8 | 7.3 |
| Rap*-ViRA | 83.7 | +10.9 | 49.2 | +16.4 | 10.3 | +3.0 | |
ViRA-Diffusion is DiffusionDrive trained with DINOv3 alignment and without auxiliary perception supervision.
| Method | NAVSIM v2 navtest EPDMS |
|---|---|
| Epona | 85.1 |
| DiffusionDriveV2 | 87.5 |
| Latent-WAM | 89.3 |
| DriveFuture | 89.9 |
| SparseDriveV2 | 90.1 |
| Discrete-WAM | 90.4 |
| ViRA-Diffusion | 92.3 |
As of October 23, 2026, ViRA-Diffusion ranks #1 on the Papers with Code NAVSIM v2 navtest leaderboard with 92.3 EPDMS.
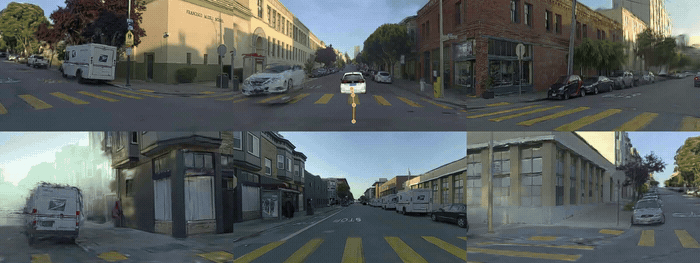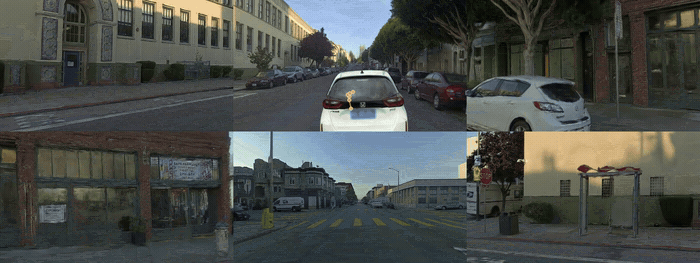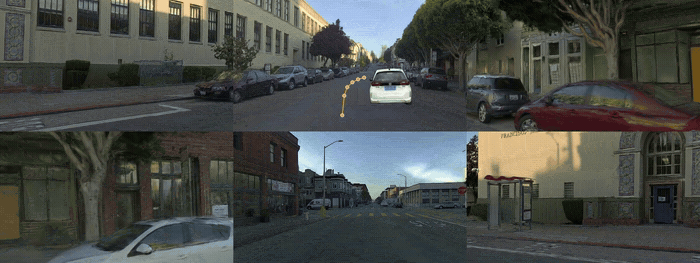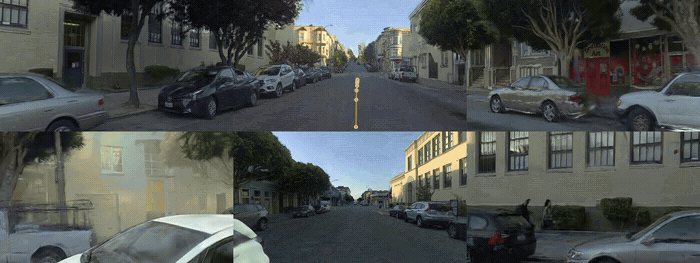
(a) Car following: the lead vehicle brakes suddenly
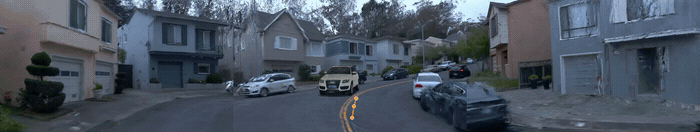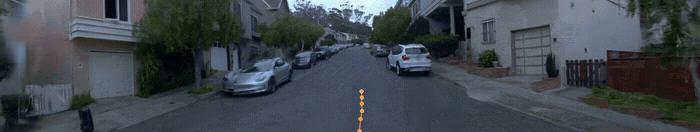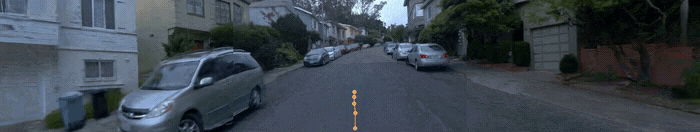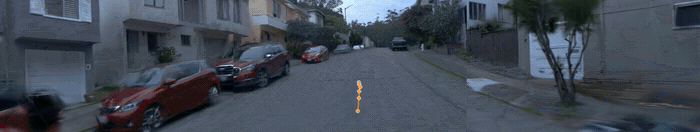
(b) Oncoming traffic: other vehicles enter the current driving area
We acknowledge all the open-source contributors for the following projects to make this work possible:
All content in this repository is under the Apache-2.0 license.
If any parts of our paper and code help your research, please consider citing us and giving a star to our repository.
@misc{zhang2026vira,
  title = {Do Better Visual Representations Always Lead to Better End-to-End Autonomous Driving?},
  author = {Zhang, Zihao and Tian, Haochen and Li, Tianyu and Jing, Changhui and He, Jingliang and Ye, Naisheng and Pu, Ziyuan and Yang, Zhenjie},
  year = {2026},
  eprint = {2610.09695},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2610.09695}
}